blog post test!
Heading 1 Heading 2 Heading 3

The SeNSE Lab of Dr. Mitra Hartmann aims to replicate the versatile activesensing behavior of whiskers in rats and mice, designing artificial whiskers that give robots a sense of touch. An important component of rodent whisker sensing is the ability to move their whiskers, a process known as “whisking”.
I was given a challenge in abstract: “Improve the way we move whiskers” . This led me to design, simulate, build, and present a biomimetic mechanism that not only replicates real biology, but proposes a new perspective on the study of neural control in rodents. This work was the topic of my MS thesis, and I’m currently adapting the work for publication.
The lab’s previous method of robotic whisking involved columns of whiskers, each actuated by its own motor. This was costly and space-inefficient.
I found inspiration in the parallel motions of multiple layers of tissue running through whisker follicles. Unlike our robot, whiskers are biologically actuated in rows.
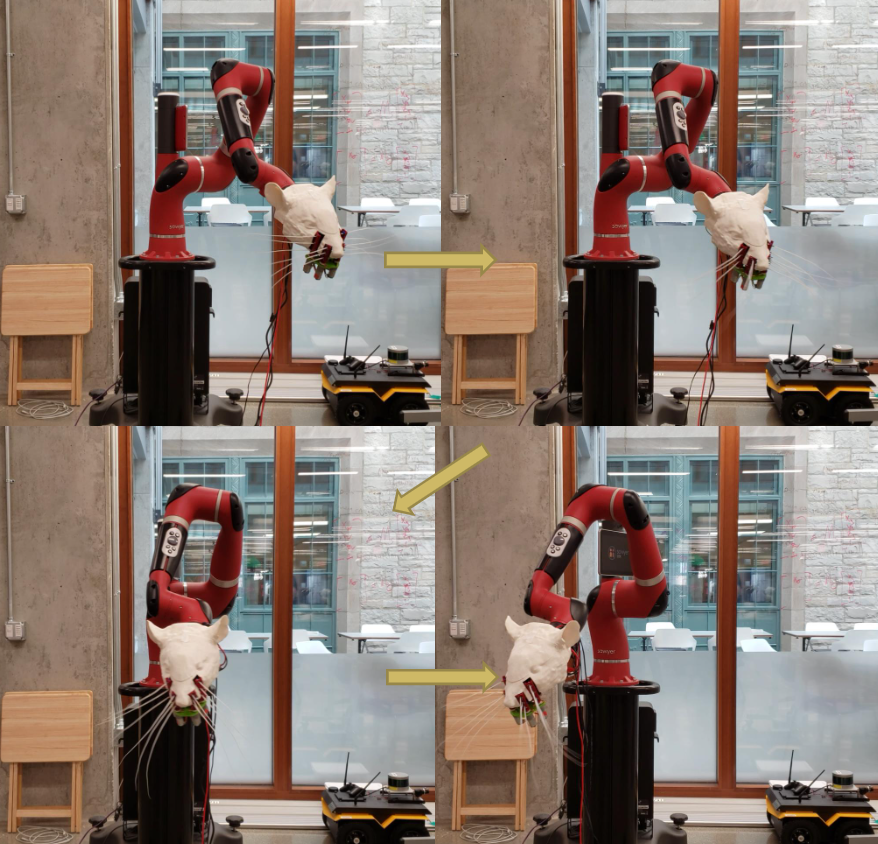
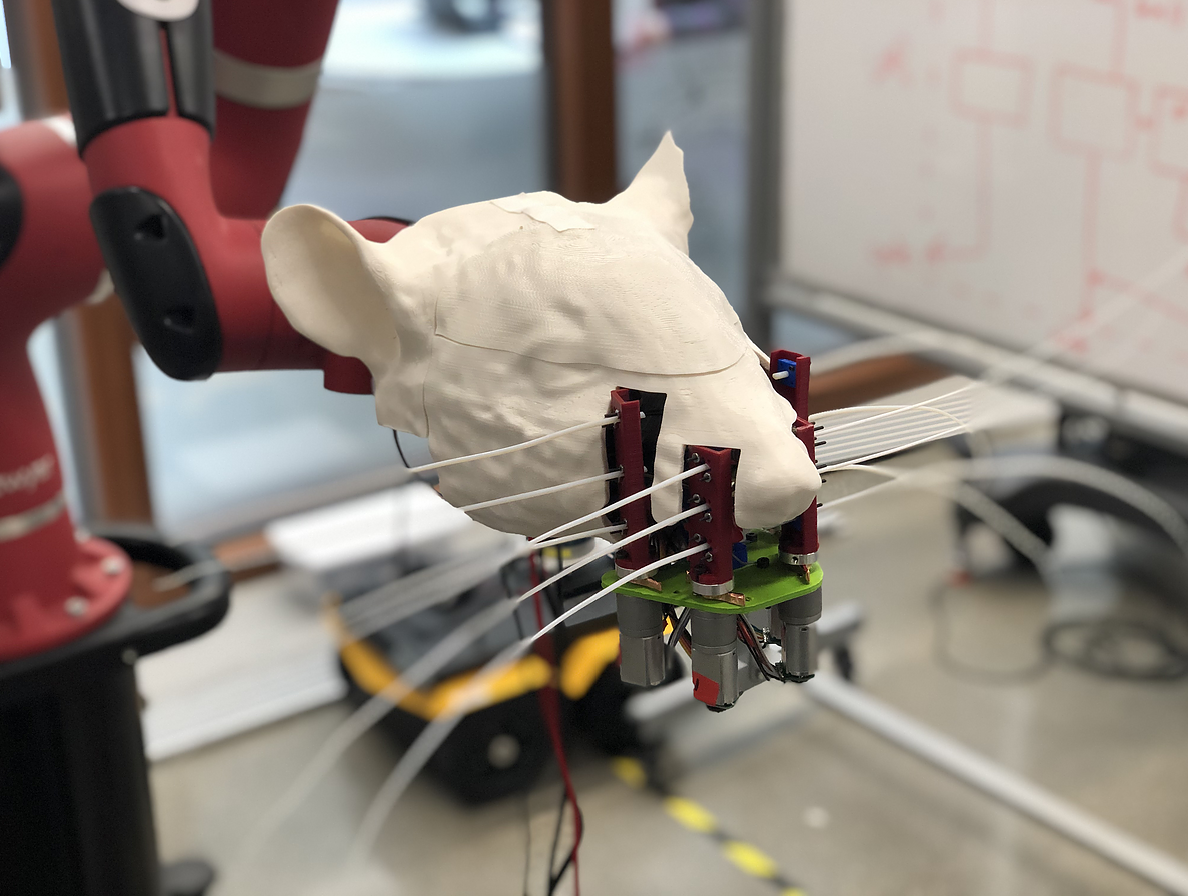

Whisker Frames is a mechanism that controls the row-wise orientation and distribution of a whisker array by the free motion of a “control frame” (CF)
Build and physical design iteration
Generating trajectories from biological data
Read the written thesis here
Heading 1 Heading 2 Heading 3